Hardware
Introduction: This section explains the electrical components used in the “
RoboCar-TriClopes
.” While some explanations of “Hardware
” also include the “Mechanics
” (as described elsewhere), Old-School separates the physical mechanical components (Mechanics
) from the electrical components (Hardware
). You could also call it “Electronics
,” and there is even a term called “Mechatoronics
.”
Circuit Boards
The functionality is determined by the circuit boards. Here, I’ll introduce the boards used inTriClops
. These boards increase integration density by stacking them. I’ll introduce them in order from the bottom up.
- **
Groovy-Quatro
**
The circuit and PCB design for the were done by Old-timer himself, as was the control firmware. However, the firmware quality was extremely poor; I2C control for the IMU (BMX055) installed initially was not implemented.Amidst this, a FA pro implemented
it for me. Since then, features such as speed servos and BNO055 support have been added, bringing it to its current state.
| Motor Controller | Schematic | IMU |
|---|---|---|
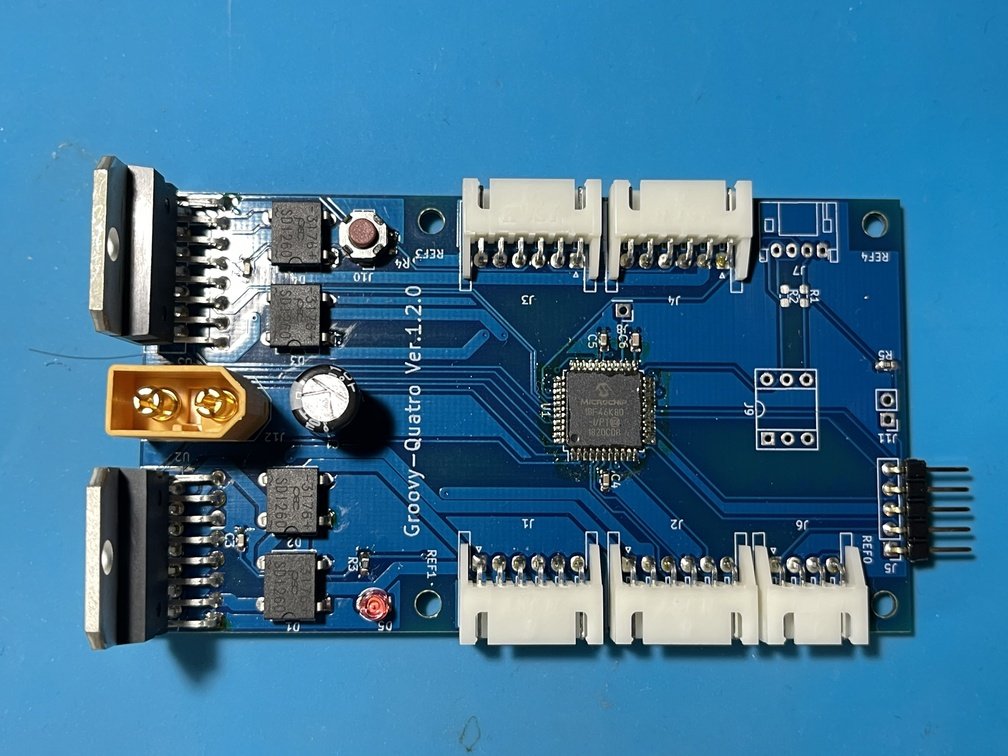
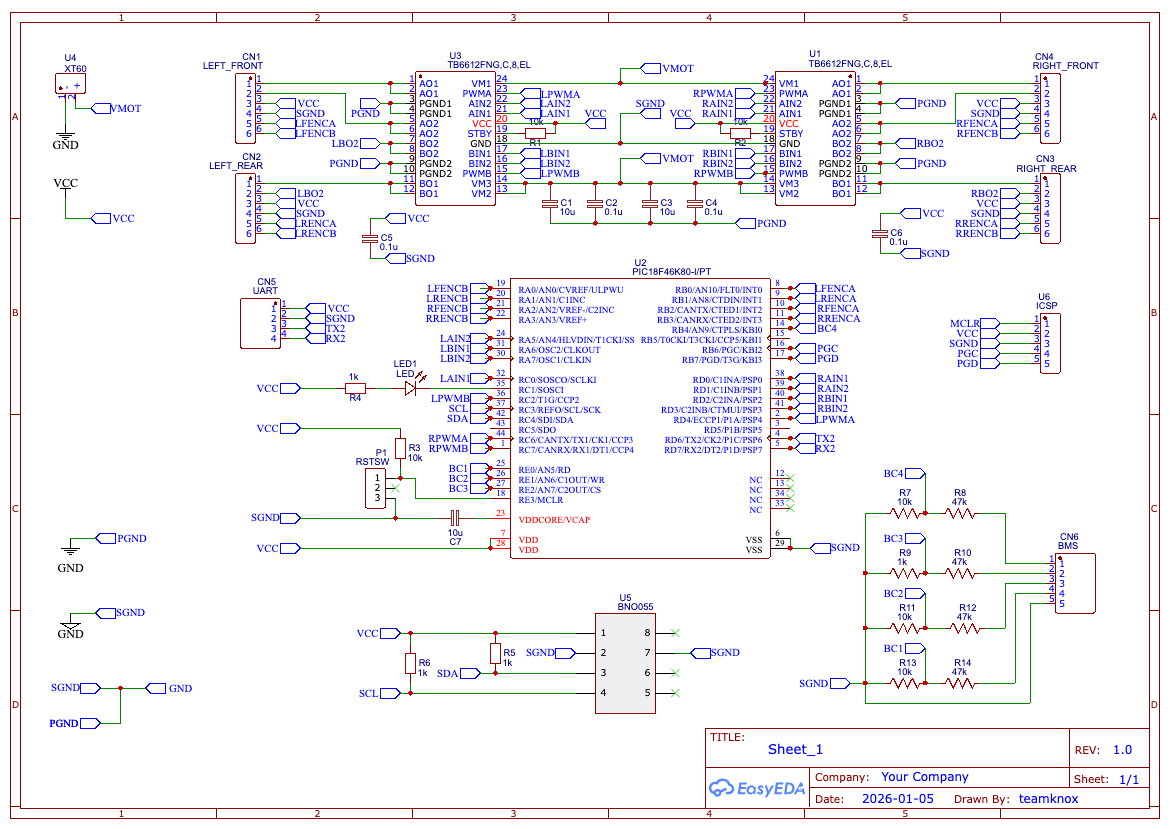
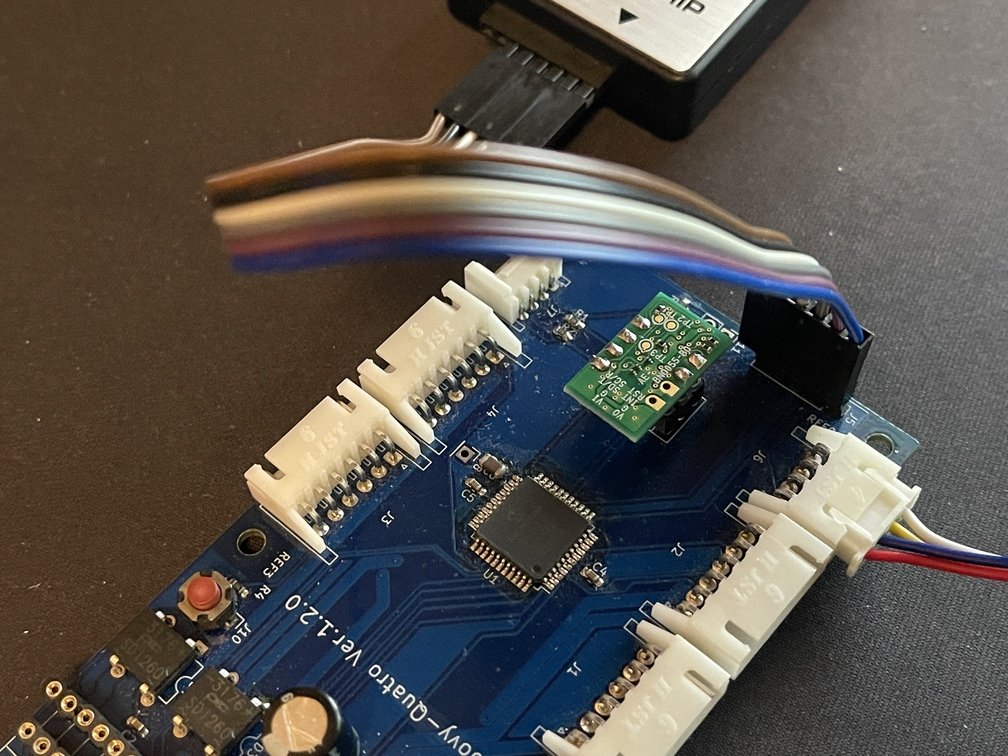
| | Before Motor Driver Replacement | Reference Diagram | Mounted Upside Down |
This board serves as the core of the Hardware
. Its main functions are as follows:
-
4-channel DC motor or BLDC (Nidec 24H) motor control
[Mechanics] As explained on the page(../mechanics/_index.md)
, this board allows independent 4-channel control of either DC motors or BLDC motors (Nidec
24H motors); mixed use is not supported.
-
Encoder Reading
The encoders built into the motors can be read independently
-
9-Channel IMU
Attitude control is possible thanks to the built-in BOSCH BNO055.
-
Drive Power Supply Monitoring via Resistor Voltage Divider + ADC
Voltage monitoring is possible for up to 4-cell LiPo batteries. This prevents over-discharge before it occurs.
-
Motor Driver Replacement
| Motor Driver | Modularization | Installation (Replacement) |
|---|---|---|
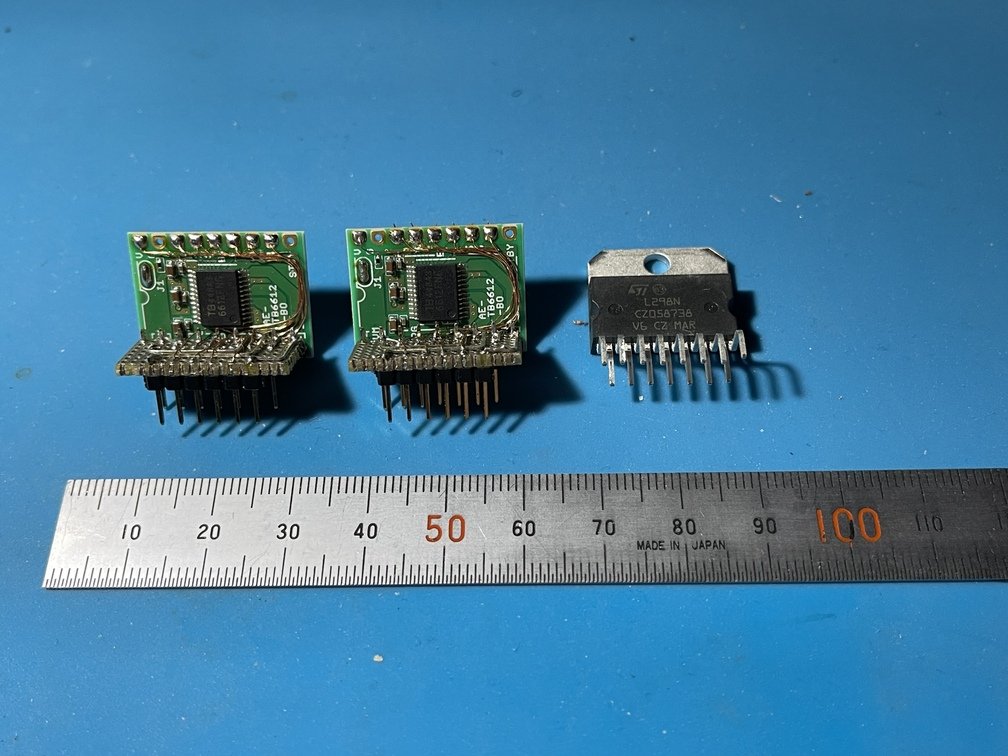
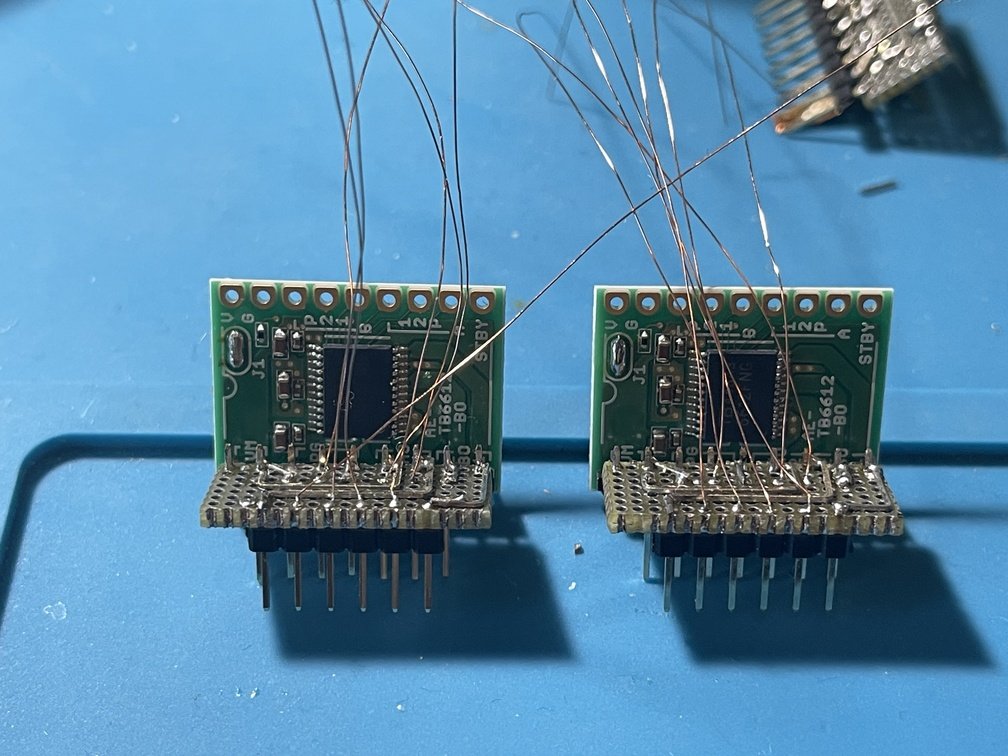
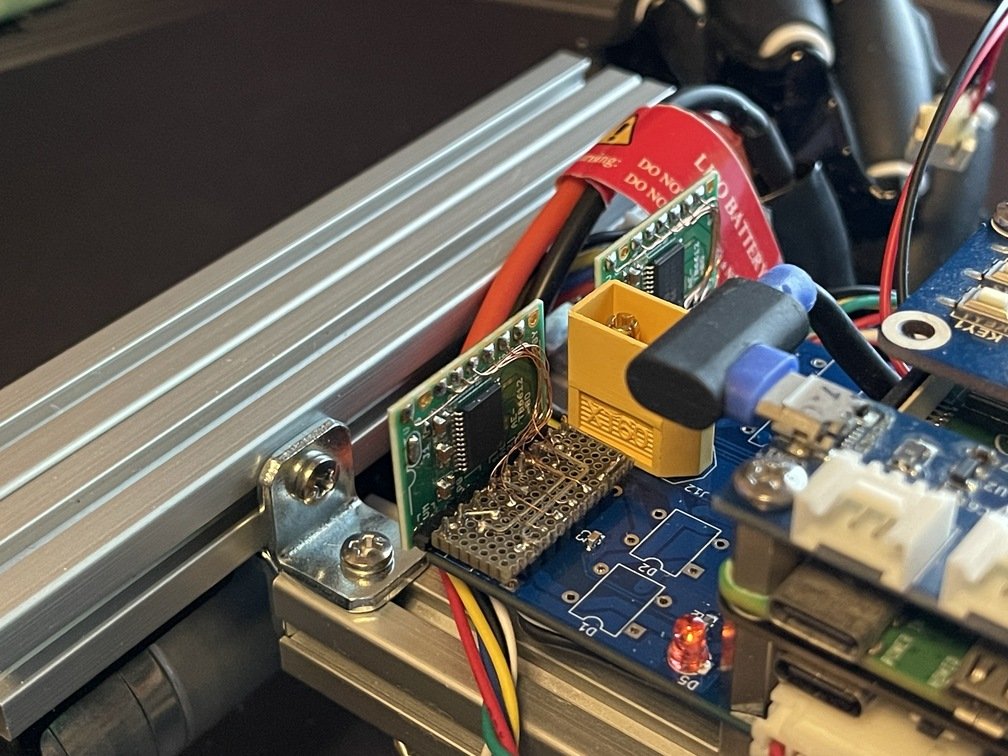
| |TB6612 and L298N|Complicated Wiring|Upgraded from L298N to TB6612|
I replaced the motor driver from the L298N
with the TB6612
.This resulted in improved power efficiency and a significant increase in motor speed, so I replaced the motor to change the gear ratio. I removed theL298N
and attempted to make the pins compatible so I could swap them out directly—it turned out to be a much harder task than I expected…
- PiSugar 3 Plus
| PiSugar 3 Plus | Wiring in progress | Assembled view |
|---|---|---|
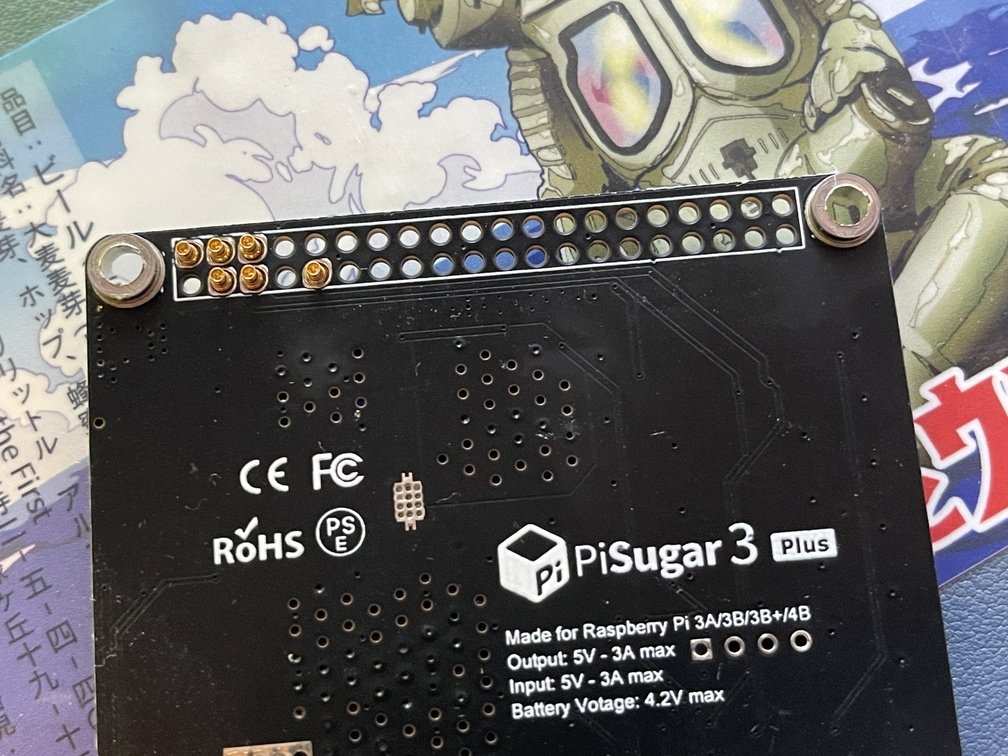
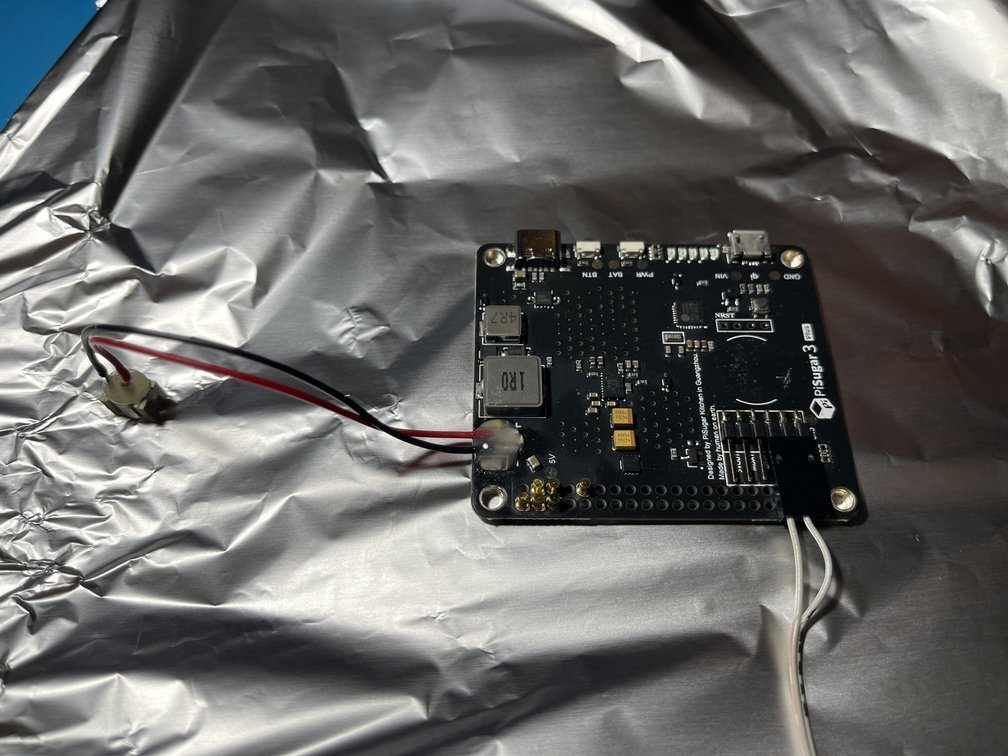
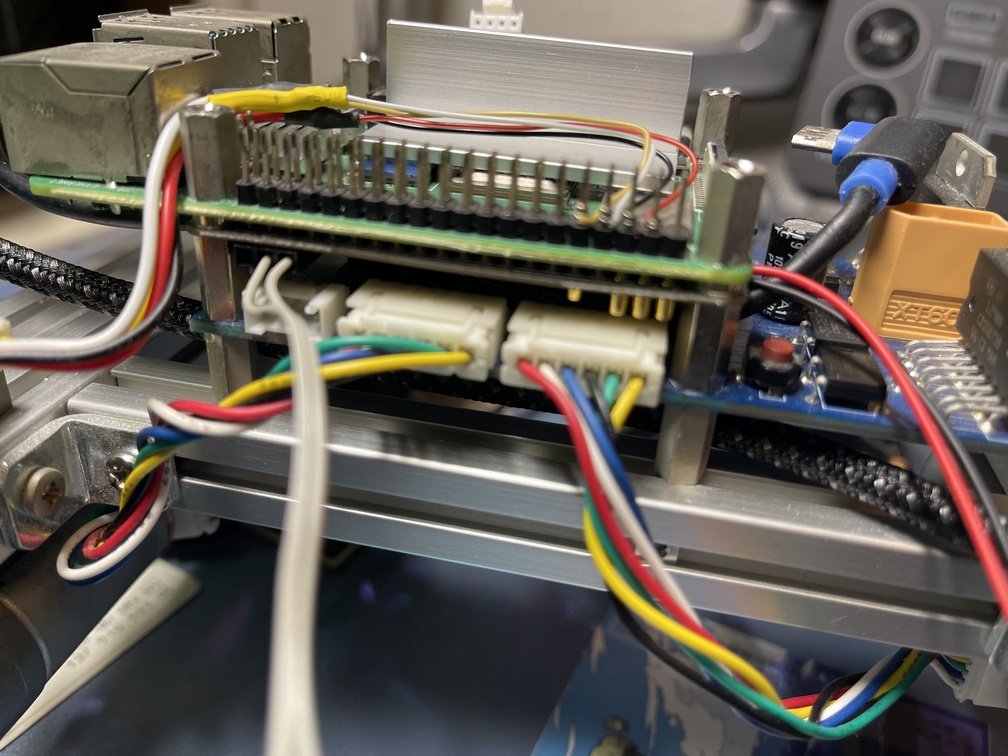
| |Logo|Aluminum foil protection to prevent solder drips|Installed at the absolute minimum height|
A battery-powered board for the Raspberry Pi. The connector section was modified to allow for stacking. The included LiPo battery was also upgraded from 5000mAh to 10000mAh.